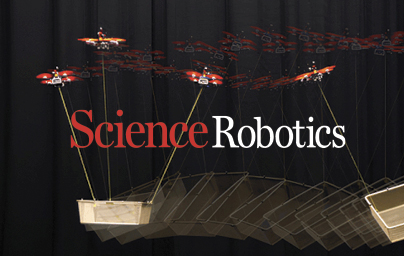
Congratulations to Marco Tognon on the publication of his article « Agile and Cooperative Aerial Manipulation of a Cable-Suspended Load » in the prestigious journal Science Robotics.
Science Robotics is one of the most influential and prestigious journals in the field of robotics. It focuses on cutting-edge research in robotics, covering topics ranging from robot engineering to their interaction with humans and the environment.
Publishing in this journal represents a significant achievement with global visibility, as Science Robotics highlights major advances in research from renowned scientists at leading universities, research institutes and major technology companies worldwide.
This work, led by Marco Tognon, an Inria researcher in the Rainbow team, and Sihao Sun, a researcher at Delft University, represents a major advance in the field of cooperative aerial manipulation. It demonstrates how several drones can coordinate in an agile, precise and robust manner to control the position and orientation of a load suspended from a cable.
The initial experiments were first carried out at IRISA and the Inria centre at the University of Rennes, before being continued and successfully completed at Delft University.
This article highlights one of Marco Tognon's main areas of research, and more generally the ongoing research work within the Rainbow research team in the field of model-based cooperative control and aerial manipulation, and the central role played by our scientists within the global robotics community.
For further information:
Science Robotics link: https://www.science.org/doi/10.1126/scirobotics.adu8015
Video link: https://www.youtube.com/watch?v=FBWN-rTK1YU&feature=youtu.be