Congratulations to the Rainbow research team for once again standing out through its numerous contributions at the international IEEE ICRA 2026, underscoring its expertise and strong reputation within the global robotics community.
The IEEE International Conference on Robotics and Automation (ICRA) is widely recognized as one of the world's leading conferences in robotics and automation. Held in Vienna, Austria, from June 1 to 5, the 2026 edition attracted more than 8,000 attendees, including researchers, engineers, and industry leaders from across the globe.
Keynote Session
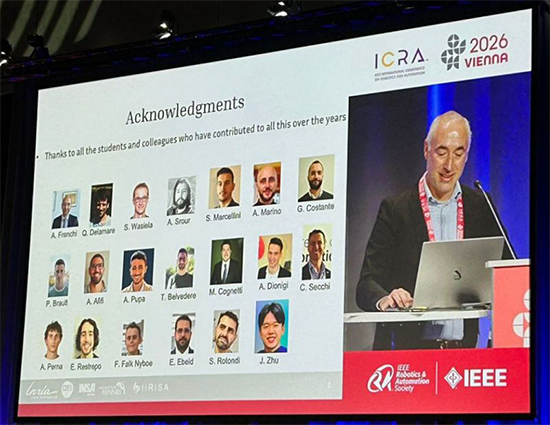
Among the plenary talks delivered by leading researchers, special mention should be made of the invited presentation by Paolo Robuffo Giordano at IEEE ICRA 2026, entitled “Intrinsic Robustness: A Journey from Control-Aware Planning to Robust Robot Learning.”
Delivering a plenary talk at ICRA represents one of the highest forms of recognition by the robotics community. This invitation provided an opportunity to showcase the work carried out by Paolo Robuffo Giordano and his team on intrinsic robustness, and on bridging the gap between simulation and real-world deployment in robotics.
Paolo Robuffo Giordano, CNRS Research Director and head of the Rainbow team, leads the HARMONY Chair Human-AI Robotic Merging for Optimal cooperatioN and efficiency)
Award
Congratulations to Claudio Pacchierotti on receiving the ICRA 2026 Conference Editorial Board Outstanding Reviewer Award, a distinction that recognizes the excellence of his contributions to the robotics research community.
Claudio Pacchierotti, is a CNRS researcher and the lead investigator of the REGO project.
Workshops
A further testament to the quality and impact of the team's research is the strong involvement of its members in workshops, demonstrating the recognition their work receives from the international robotics community.
"Contact-Robust Trajectory Planning via Parametric Sensitivity Analysis for Hybrid Robotic Systems" with Tommaso Belvedere, James Zhu, Marco Cognetti
"Decentralized Reinforcement Learning for Multi-Agent Multi-Resource Allocation via Dynamic Cluster Agreements" with Antonio Marino, Esteban Restrepo, Claudio Pacchierotti
"QP-Based Inner-Loop Control for Constraint-Safe and Robust Trajectory Tracking for Aerial Robots" with Lorenzo Balandi, Marco Tognon
Papers
Among the team's contributions to the conference were the following three papers:
"On the Computation of Sensitivity Tubes" (ThI2I.16) — avec Andrea Pupa, Tommaso Belvedere, Cristian Secchi
"Impact-Robust Posture Optimization for Aerial Manipulation" (ThI2I.189) — avec Amr Afifi, Ahmad Gazar, Javier Alonso-Mora, Antonio Franchi
"Distributed Multi-Robot Active-Sensing of a Diffusive Source" (ThI2I.324) — avec Francesca Pagano, Nicola De Carli, Esteban Restrepo, Antonio Marino
Congratulations to Paolo Robuffo Giordano, Claudio Pacchierotti, Marco Tognon, Esteban Restrepo, Tommaso Belvedere, Marco Cognetti et Lorenzo Balandi
"Robotics: internationally renowned research in Rennes" – an article by the University of Rennes (in french only)
Read the article by the University of Rennes, dedicated to the Rainbow research team (in french only)
Good reviewing is part of what keeps research strong and accountable. In a time when generating text is easier than ever, thoughtful and constructive human judgment feels more important than ever.
Many thanks to the ICRA organizers and to all the colleagues who dedicate their time to supporting the peer-review process